Aero-Maverick Technologies · A Maverick Technologies company

Swarms thatkeep flyingwithout GPS.

We build autonomy for drones that work together: decentralised swarm control, GPS-denied navigation, safety layers that check every command, and simulators that train pilots on real ArduPilot firmware.

Swarm formation · live--:--:-- PKT
Agents 5/5Links —Form. err —GPS Denied

Pointer pushes · click scatters

Aero-Maverick Technologies33.6425° N 72.9906° EA Maverick Technologies company
01FocusWhat we work on

Autonomy that holds up
when things break.

  1. SWM/01

    Swarm autonomy

    Leaderless formation control where every drone senses only its neighbours, and the formation survives packet loss, delay and a lost agent.

  2. GPS/02

    GPS-denied navigation

    Localisation from odometry, landmarks, LiDAR and neighbours, for places where satellite positioning is jammed or unavailable.

  3. SAF/03

    Safety layers

    Control-barrier-function filters and rule-based shields between the planner and the autopilot, so a bad command never reaches the motors.

  4. SIM/04

    Simulation & training

    Software-in-the-loop with ArduPilot and PX4, and a pilot trainer that flies each drone with its own parameter file.

02Products & researchSoftware, ground systems, research

What we
have built.

Every number here comes from a test run or a flight log. Where something is still in simulation, we say so.

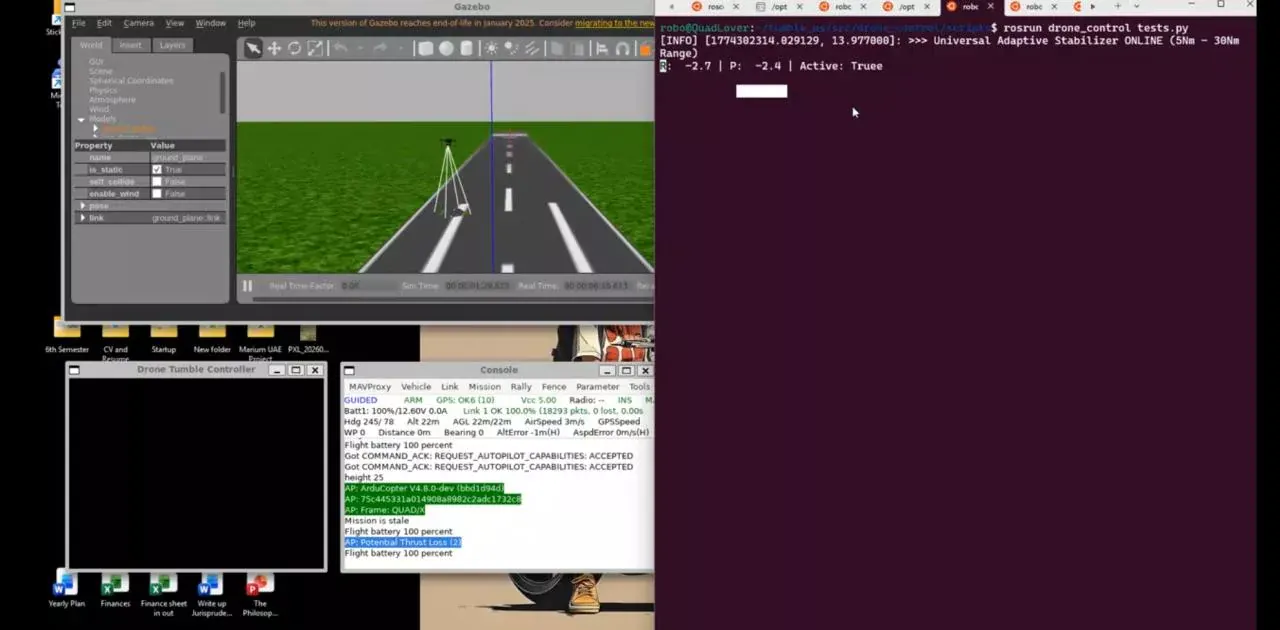
Aeromaverick SimAM-SIMFig. 01

Product · Pilot training2026

Aeromaverick Sim

A desktop multirotor training simulator that flies each drone with its own ArduPilot parameter file: 6-DOF physics with battery sag, wind and ground effect, plus real ArduCopter SITL lock-stepped at 1,200 Hz.

Stack
Three.js · Electron · MAVLink
Missions
12, scored with debrief
Tests
31, incl. closed-loop flight

Windows · evaluation build v0.2Download ↗
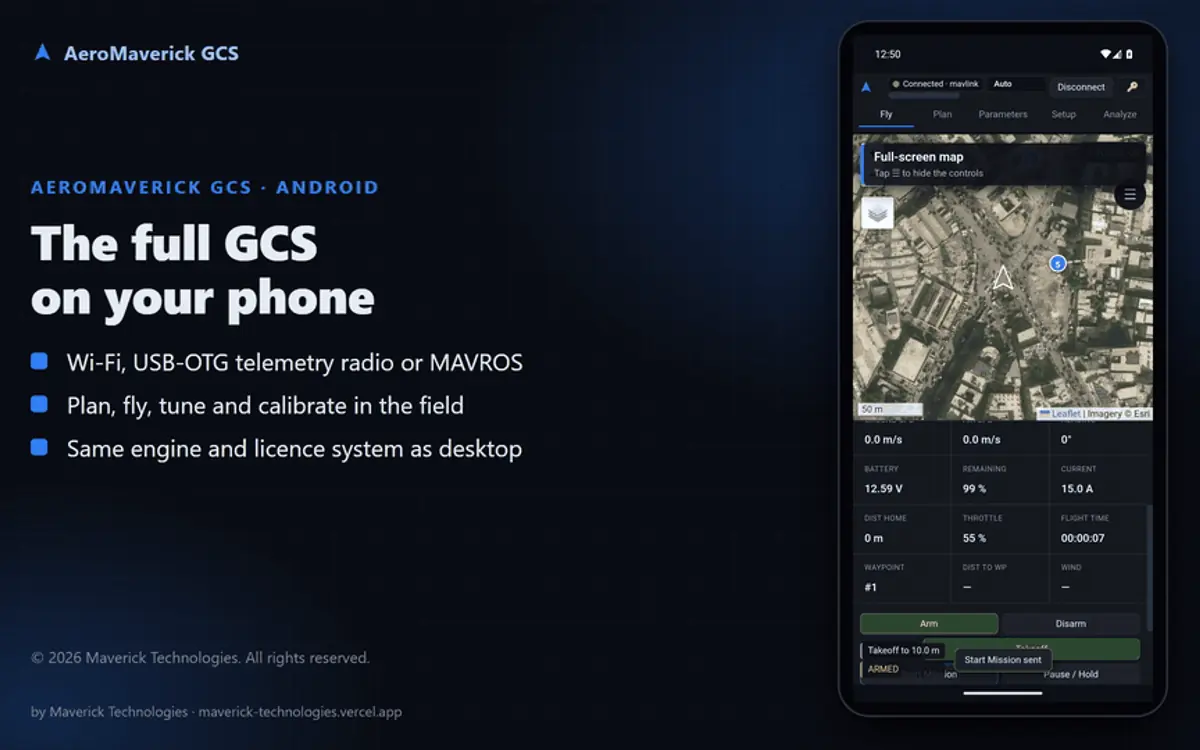
AeroMaverick GCSAM-GCSFig. 02

Product · Ground control2026

AeroMaverick GCS

A ground control station for PX4 and ArduPilot aircraft, rovers, boats and subs, over MAVLink or MAVROS (ROS 1 and ROS 2). Mission planning, parameters, calibration, log analysis, live video and multi-vehicle swarms, with the same engine on Windows and Android.

Autopilots
PX4 · ArduPilot
Links
MAVLink 2 · MAVROS
Swarm
Central & onboard follow

v1.1 · Windows & AndroidDownload ↗

Resilient Swarm FormationAM-SWMFig. 03

Research · Swarm control2026

Resilient Swarm Formation

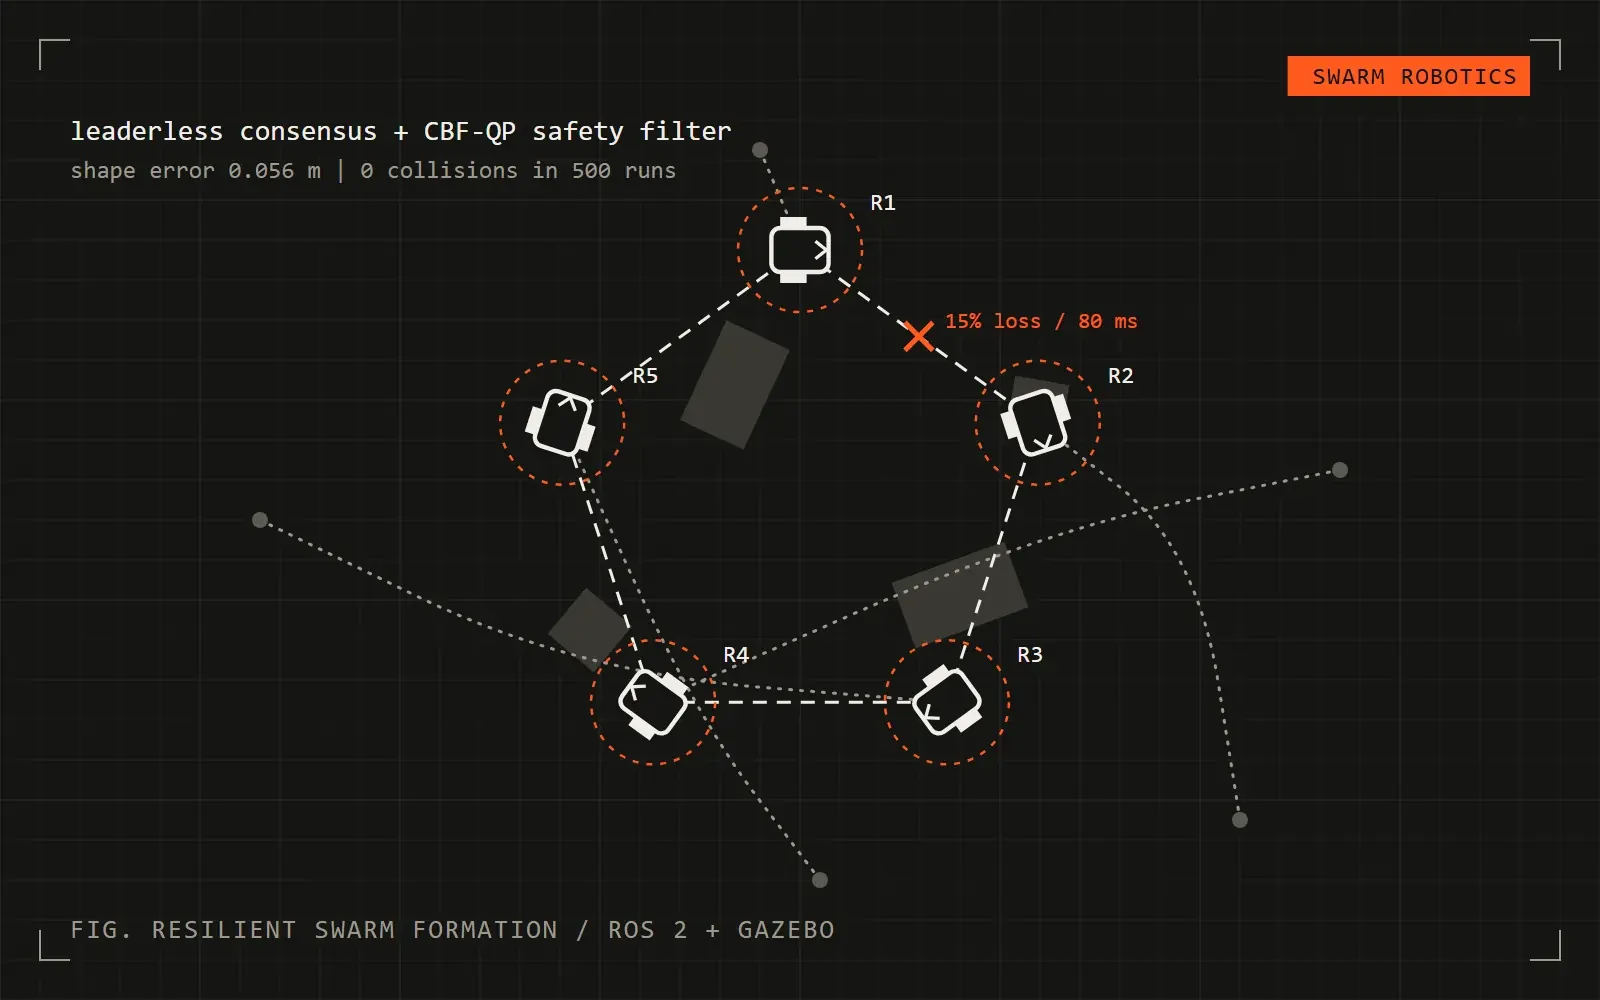
Five robots, no GPS, each sensing only its neighbours within 6 m. A control-barrier-function filter checks every command, and the pentagon still forms with 50% packet loss and a robot down.

Stack
ROS 2 Jazzy · Gazebo Harmonic
Runs
550 across 22 conditions
Safety on
500 / 500 collision-free

Open sourceSource ↗

LiDAR Forest Flight with RLAM-RLFig. 04

Research · Safe RL2026

LiDAR Forest Flight with RL

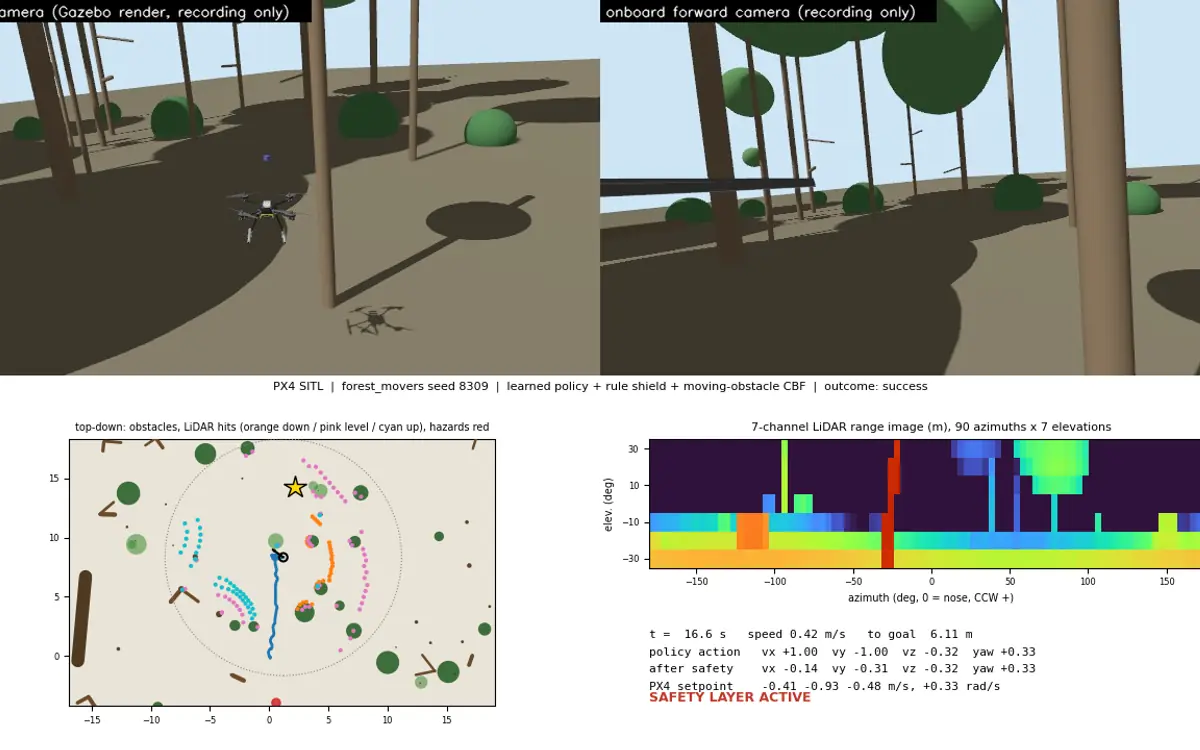
A PPO policy that steers a drone through dense procedurally generated forest using only its own 3-D LiDAR, wrapped in a rule-based shield and a CBF filter, trained on a single laptop CPU.

PX4 SITL
10 / 10 flights, no contact
Moving hazards
Collisions 16% → 4%
Training
1.2M+ steps

Open source · simulationSource ↗

Fail-Safe Indoor NavigationAM-NAVFig. 05

Research · GPS-denied2026

Fail-Safe Indoor Navigation

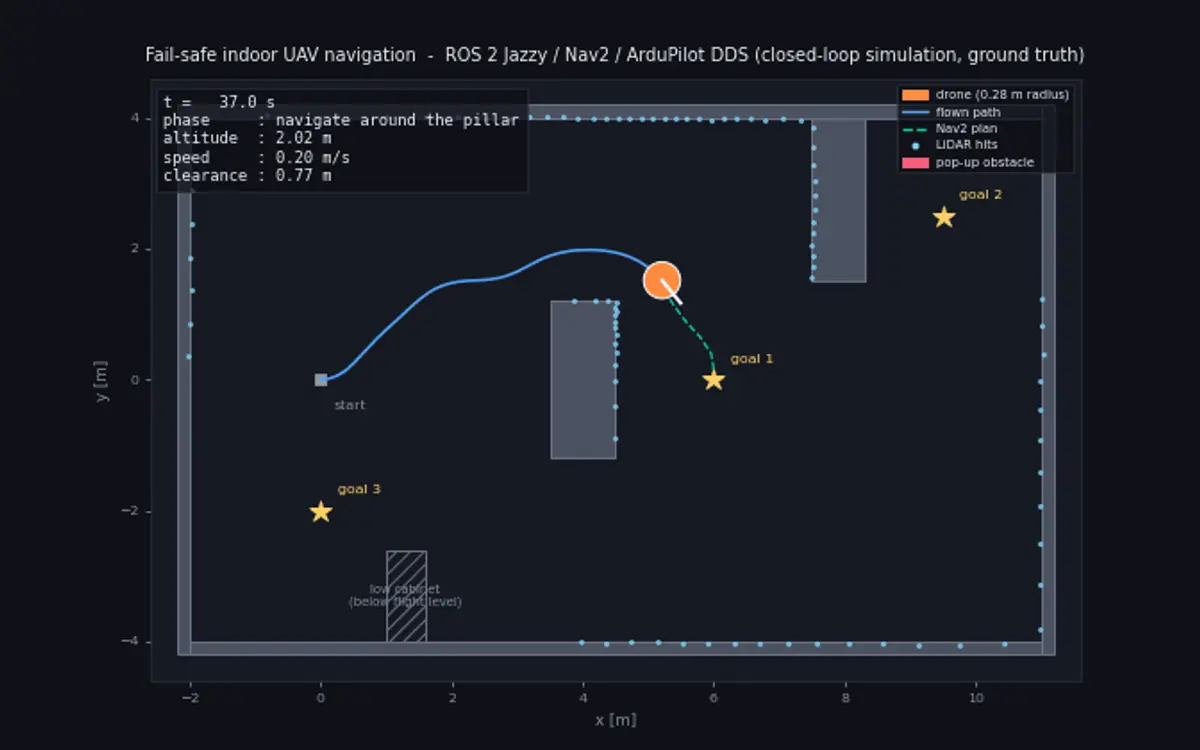
Indoor, GPS-denied flight with ROS 2 Nav2, SLAM Toolbox and ArduPilot over DDS. Navigation is kept apart from a layered safety chain, so a sensor dropout, a hung node or lost localisation never leaves the drone flying on a stale command.

Stack
ROS 2 Jazzy · Nav2 · ArduPilot
Scenarios
12 / 12 pass, 5 runs in a row
Pop-up obstacle
0.6 m ahead: stops, then detours

Open source · simulationSource ↗

Medical Response DroneAM-MEDFig. 06

Research · Delivery2026

Medical Response Drone

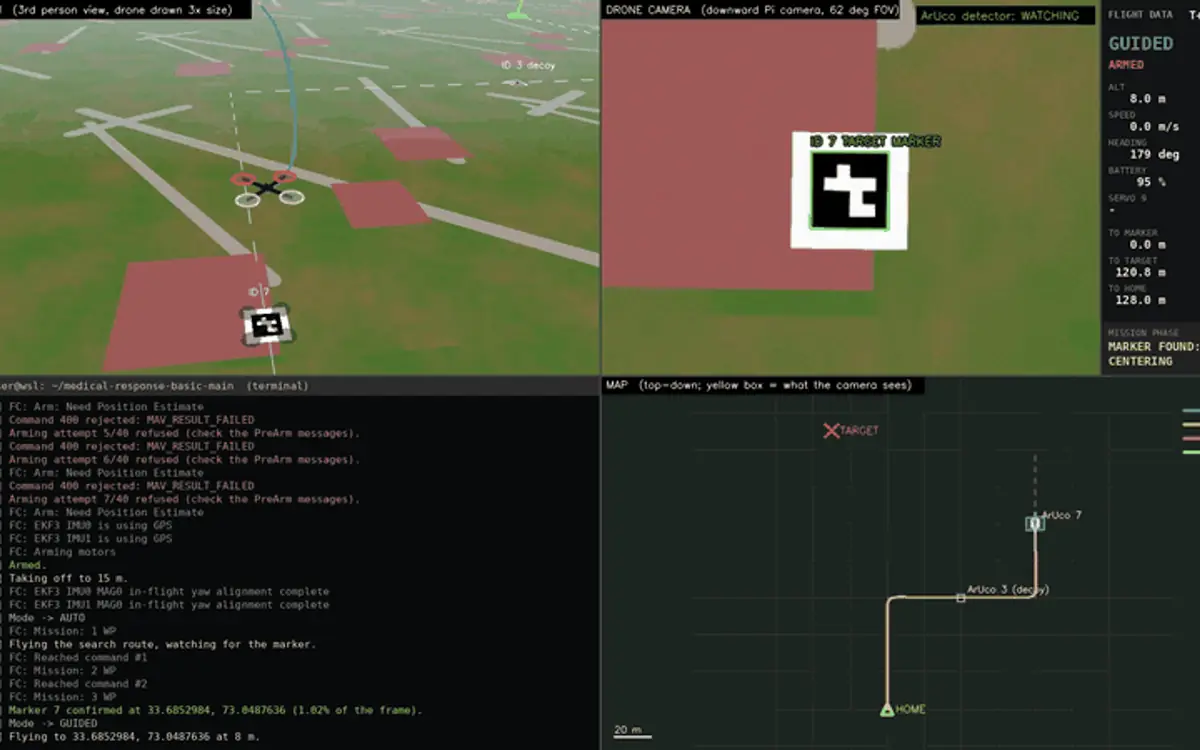
An ArduPilot quadcopter searches a route for an ArUco marker, lands precisely on it, picks up a payload, delivers it to a GPS point and returns home, with pre-flight and in-flight safety checks the whole way.

Marker landing
0.01–0.02 m error
Payload drop
0.3–0.8 m from target
Return to launch
0.04 m error

Open source · ArduPilot SITLSource ↗

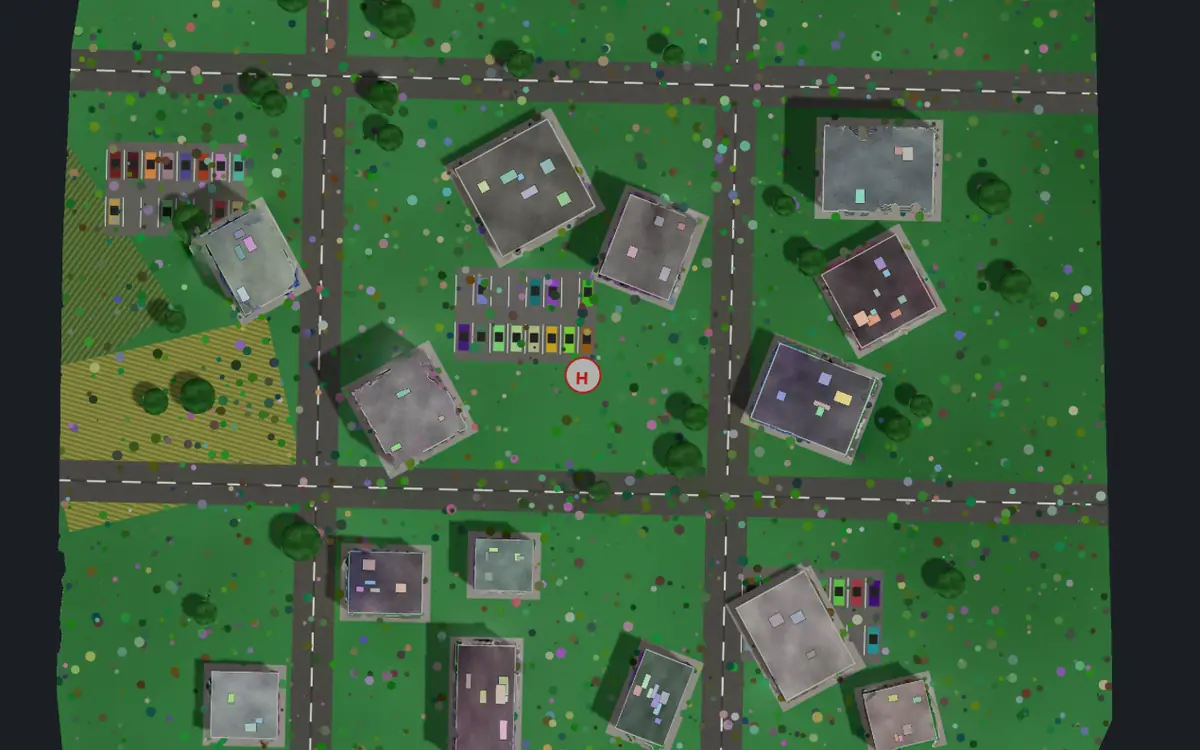
Autonomous Drone MappingAM-MAPFig. 07

Product · Survey & mapping2026

Autonomous Drone Mapping

Plan a survey from a GeoTIFF, fly it autonomously with ArduPilot and MAVROS, capture geotagged photos at the right overlap, and build an orthophoto, elevation model and 3D model in WebODM.

Photos (sim)
195 / 195 reconstructed
Orthophoto
3 cm per pixel
Height check
22.3 m vs 22.2 m true

Flight-tested · v2 verified in SITLSource ↗

APF-Nav Obstacle AvoidanceAM-APFFig. 08

Research · Path planning2026

APF-Nav Obstacle Avoidance

A quadrotor flies a waypoint mission through an indoor hangar with no prior map, using only a 270° lidar. Each waypoint pulls, each obstacle pushes, and vortex repulsion with local-minimum escape keeps it from getting stuck.

Stack
ROS Noetic · Gazebo 11
Waypoints
10 / 10, 4 runs in a row
Collisions
0

Open source · GazeboSource ↗

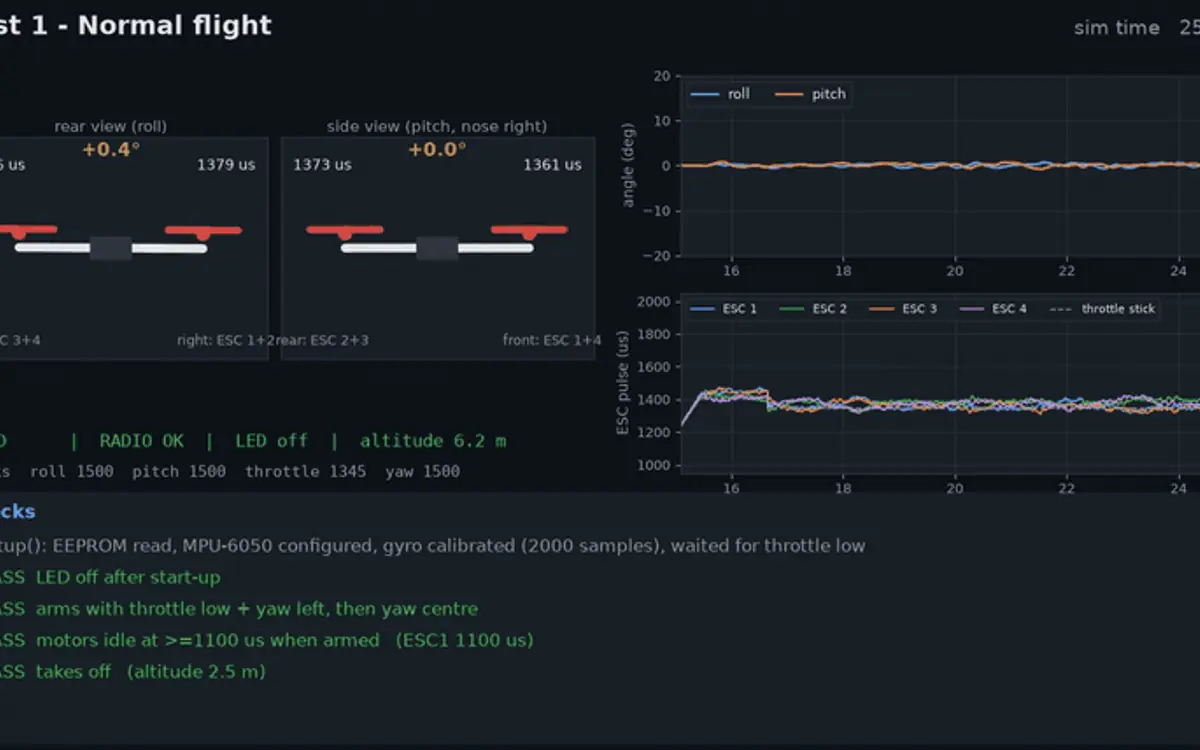
Arduino F450 Flight ControllerAM-FCFig. 09

Hardware · Flight control2026

Arduino F450 Flight Controller

A self-levelling flight controller for an F450 quadcopter on an Arduino Uno or Nano with an MPU-6050, with radio-loss failsafe, gyro-failure protection and a PC simulator that runs the real Arduino code.

Flight tests
42 / 42 checks passed
Radio lost
Motors stop in 88 ms
Robustness
23 / 23 F450 builds

Open source · tested in simulationSource ↗

03MilestonesPitches & programmes

From lab bench
to pitch deck.

  1. 2026PITCH

    DEFTECH Incubation Program

    Selected to pitch · 400+ applications, 50+ shortlisted

    Pitched Aero-Maverick Technologies to the National Science & Technology Park, NUST and THE AKD GROUP (UK): autonomous UAV swarm systems for GPS-denied environments.

  2. 2026PITCH

    NERC · NUST CEME

    Startup pitch · drone swarms & multi-UAV systems

    Presented our vision for coordinated autonomous drones to industry professionals, researchers and fellow innovators.

Proving groundOur ideas get tested in competition by Team Aero Mavericks, our student UAV team at NUST SEECS. →

04Join usApplications open all year

Fly with Aero-Maverick.

We need engineers who want to make drones work together: autonomy, embedded systems, simulation and ground software. Students and graduates are both welcome.

  • Swarm autonomy & control
  • Embedded & flight hardware
  • Simulation & SITL
  • Ground control software
  • Computer vision
  1. 01ApplyFill in the form. It takes about three minutes.
  2. 02ChatWe reply within a week and set up a short call or meet-up.
  3. 03BuildYou join a project and ship something real in your first month.

Application formOpen in new tab ↗

05ContactProjects, partnerships & questions

Need drones that work together?

We’re looking for research partners, pilots for our training simulator, and organisations with a use for coordinated autonomous drones.

Find us
LinkedIn · GitHub
Based in
Islamabad, Pakistan

Send a message→ aeromavericks.nust@gmail.com

Opens your email app with the message filled in. Nothing is stored on this site.